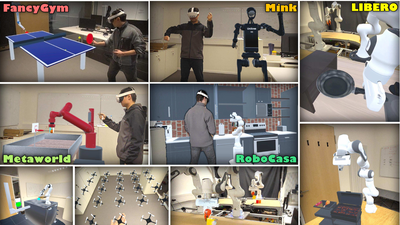
IRIS: An Immersive Robot Interaction System
IRIS supports immersive robot interaction and demonstration collection across simulation and real-world settings.
Robotics researcher · Karlsruhe Institute of Technology
I study how people can teach robots more naturally—and how robots can turn demonstrations and multimodal observations into capable behavior.
I am a PhD student in the Intuitive Robot Lab and Autonomous Learning Robots Lab at KIT, supervised by Rudolf Lioutikov and Gerhard Neumann. I previously earned bachelor's and master's degrees in Mechanical Engineering from Harbin Institute of Technology.

Immersive and augmented reality interfaces for collecting demonstrations and making robot interaction more intuitive. See IRIS and the AR interface study.
Learning from demonstrations and designing useful action representations. This work includes D3IL and BEAST.
Bringing geometry, vision, and high-frequency sensing into robot policies. See PointMapPolicy and DAM-VLA.
Selected work
IRIS supports immersive robot interaction and demonstration collection across simulation and real-world settings.
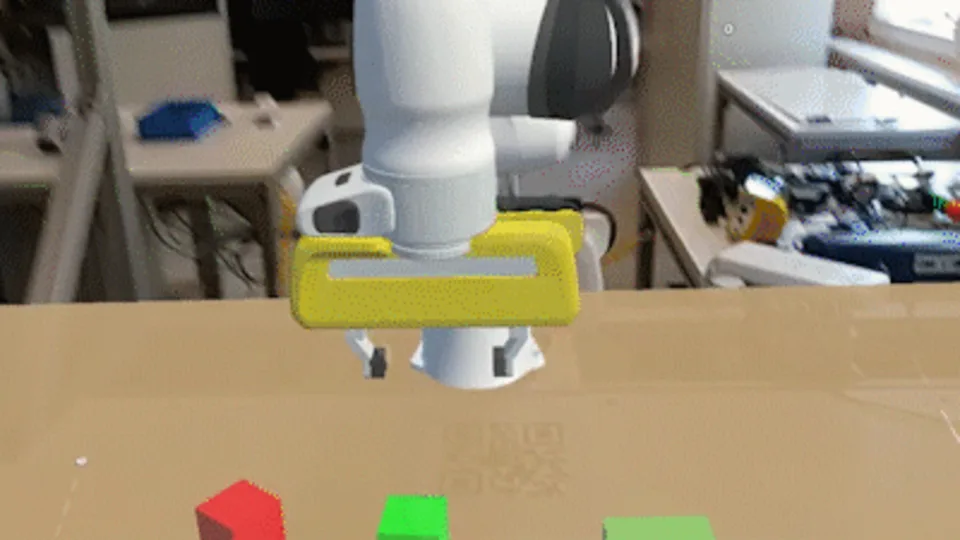
A user study compares augmented reality interfaces for collecting robot demonstrations and introduces virtual kinesthetic teaching.
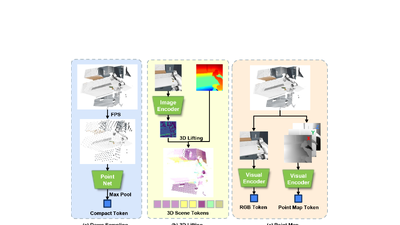
Structured point-cloud processing supports multimodal imitation learning for robot manipulation.
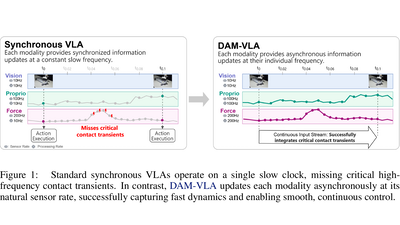
Asynchronous processing lets vision, force, and other modalities update at their natural rates for reactive robot control.
Recent updates
| Sep 04, 2026 |  Our paper DAM-VLA: Decoupled Asynchronous Multimodal Vision Language Action Model has been accepted to CoRL 2026! |
|---|---|
| Sep 19, 2025 | Our two papers accepted at NeurIPS 2025 |
| Aug 01, 2025 | Our paper IRIS: An Immersive Robot Interaction System has been accepted to CoRL 2025! The project page includes the paper, code, and demonstrations. |
Interested in robot learning, interaction, or research collaboration? Email me.
